Jump to navigation

Logo RUB
  • News
  • Team
  • Teaching
  • Research
  • Contact
  • Deutsch
  • DE
MENU
  • LinkedIn
    • News
    • Team
    • Teaching
    • Research
    • Contact

- Ruhr-Universität Bochum

Automatic Control and Systems Theory

Flight controllers for stabilizing drones, speed controllers for wind turbines or optimal energy flow control in a modern building – practically every complex technical system requires controllers for its stabilization and optimization. The control engineering methods investigated and used at the chair of Automatic Control and Systems Theory are always digital, inseparably linked to IT…

… and ultimately defined by software that implements numerical control algorithms. One special feature is that the real-time capability of the algorithms is key, as a drone cannot wait for its IT to boot up or install updates during flight. Another special feature is the close integration of software and hardware, since unlike in consumer products such as PCs or smartphones, the most powerful hardware is not always the most attractive one for closed-loop control applications. Because factors such as space requirements, costs and energy consumption of the hardware have to be taken into account, closed-loop control technology is often implemented on microcontrollers that are as slim and cost-effective as possible. We focus on closed-loop control algorithms, the software required to implement them and the underlying system models (real-time simulation models). Many of the algorithms and methods we investigate or use are essentially based on numerical optimization methods, where real-time implementation on microcontrollers is a particular challenge. In our research projects we regularly investigate algorithmic principles by simulation and also implement IT for control engineering tasks in practical applications together with industrial partners.

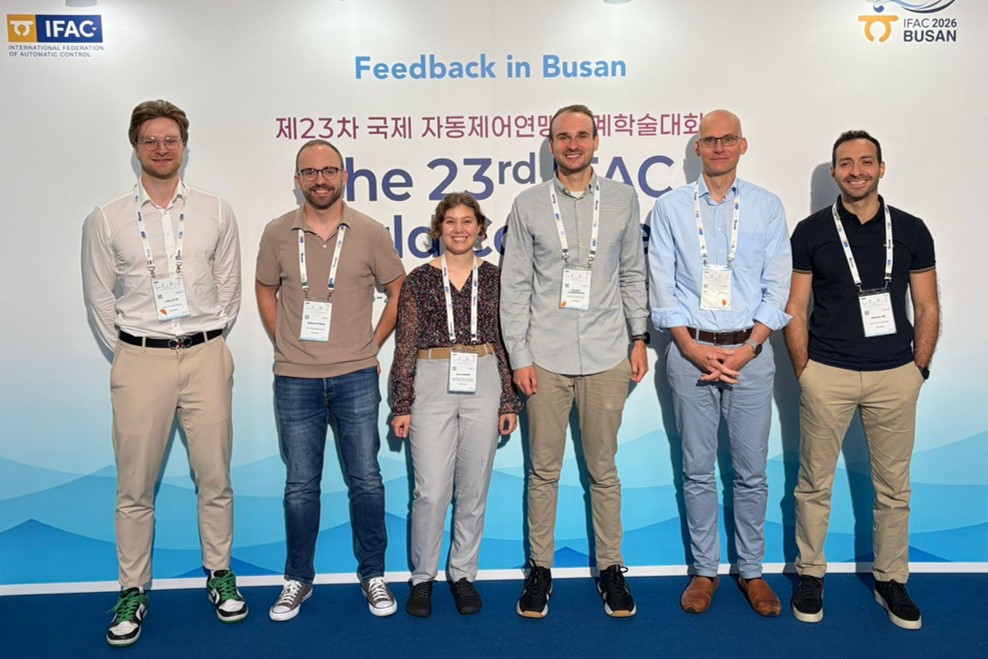
IFAC WC 2026

23rd IFAC World Congress

Julian Otte, Raphael Dyrska, Nora Lindner, Benedikt Lammersmann, and Ali Mjalled presented research results at the 23rd IFAC World Congress.

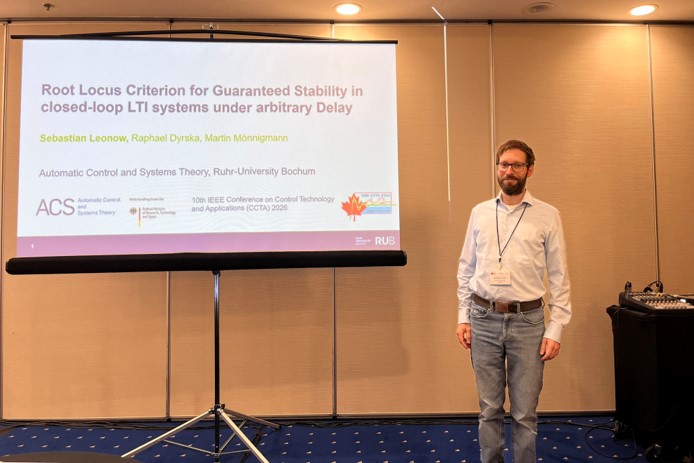
CCTA 2026

10th IEEE Conference on Control Technology and Applications

Sebastian Leonow presented current results on controller tuning in systems with significant delays at the Conference on Control Technology and Applications (CCTA) 2026.

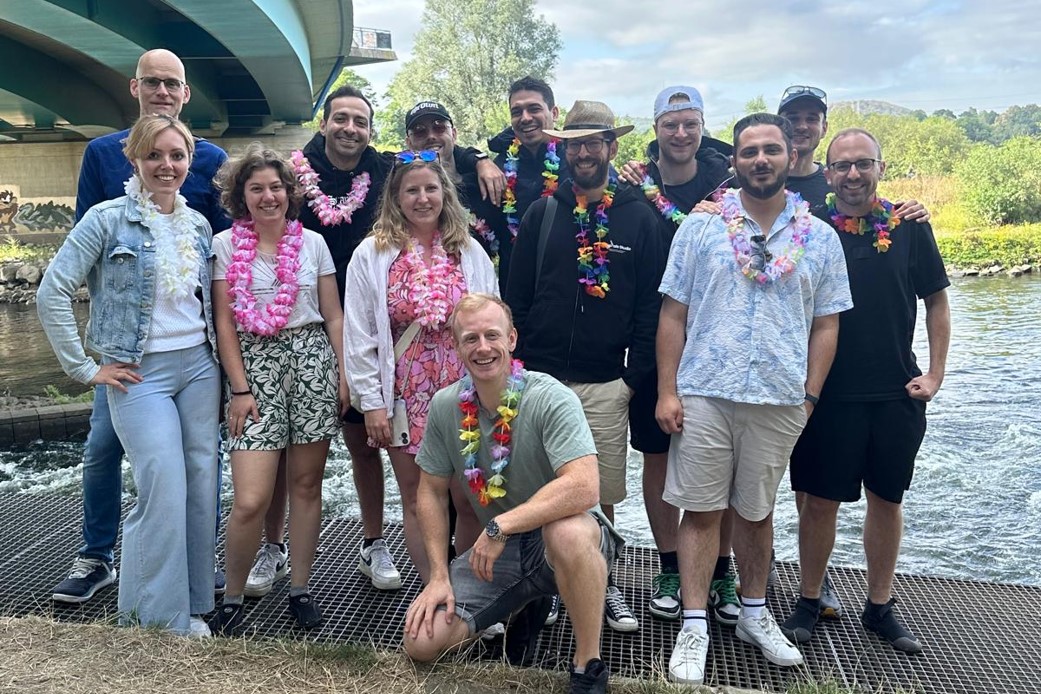
Excursion 2026

Rafting Trip on the Ruhr

At regular intervals, the Chair of Automatic Control and Systems Theory organizes an excursion in and around Bochum to promote team building through a variety of activities. This year, the chair headed to the Ruhr River for a rafting trip.

ECC 2026

24th European Control Conference

Benedikt Lammersmann presented current results on the online detection of inactive constraints in the context of model predictive control at the European Control Conference 2026.

FUSION 2026

29th International Conference on Information Fusion

David Müller presented current research results on UAV attitude estimation at the International Conference on Information Fusion in Trondheim, Norway.

Kickoff Meeting

Project KLEEnOPT

Together with partners from RUB and industry, ACS optimizes wastewater treatment processes in realtime.

More news

Team

People at the chair of Automatic Control and Systems Theory

more information

Teaching

An overview over lectures and student theses

more information

Contact

Postal and package addresses, contact persons

more information
Logo ISSE
Privacy Policy
Legal Notice (RUB)
Contact (RUB)
Automatic Control and Systems Theory
Ruhr University Bochum
Universitätsstraße 150
44801 Bochum
Germany
Back to Top